DIY bipedal walking robot: Build and Tune Your First Bot
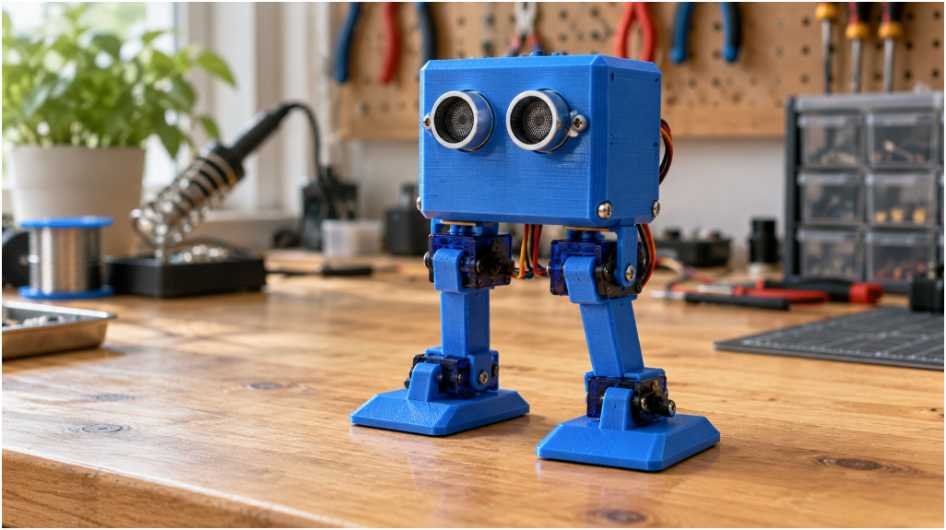
A robot that moves its legs but keeps falling needs more than faster code. For a DIY bipedal walking robot, I would start with four servos, a light frame, and careful calibration. The first goal is controlled weight transfer, followed by repeatable steps. My approach puts standing, tilting, and power checks ahead of walking. That […]
Read more